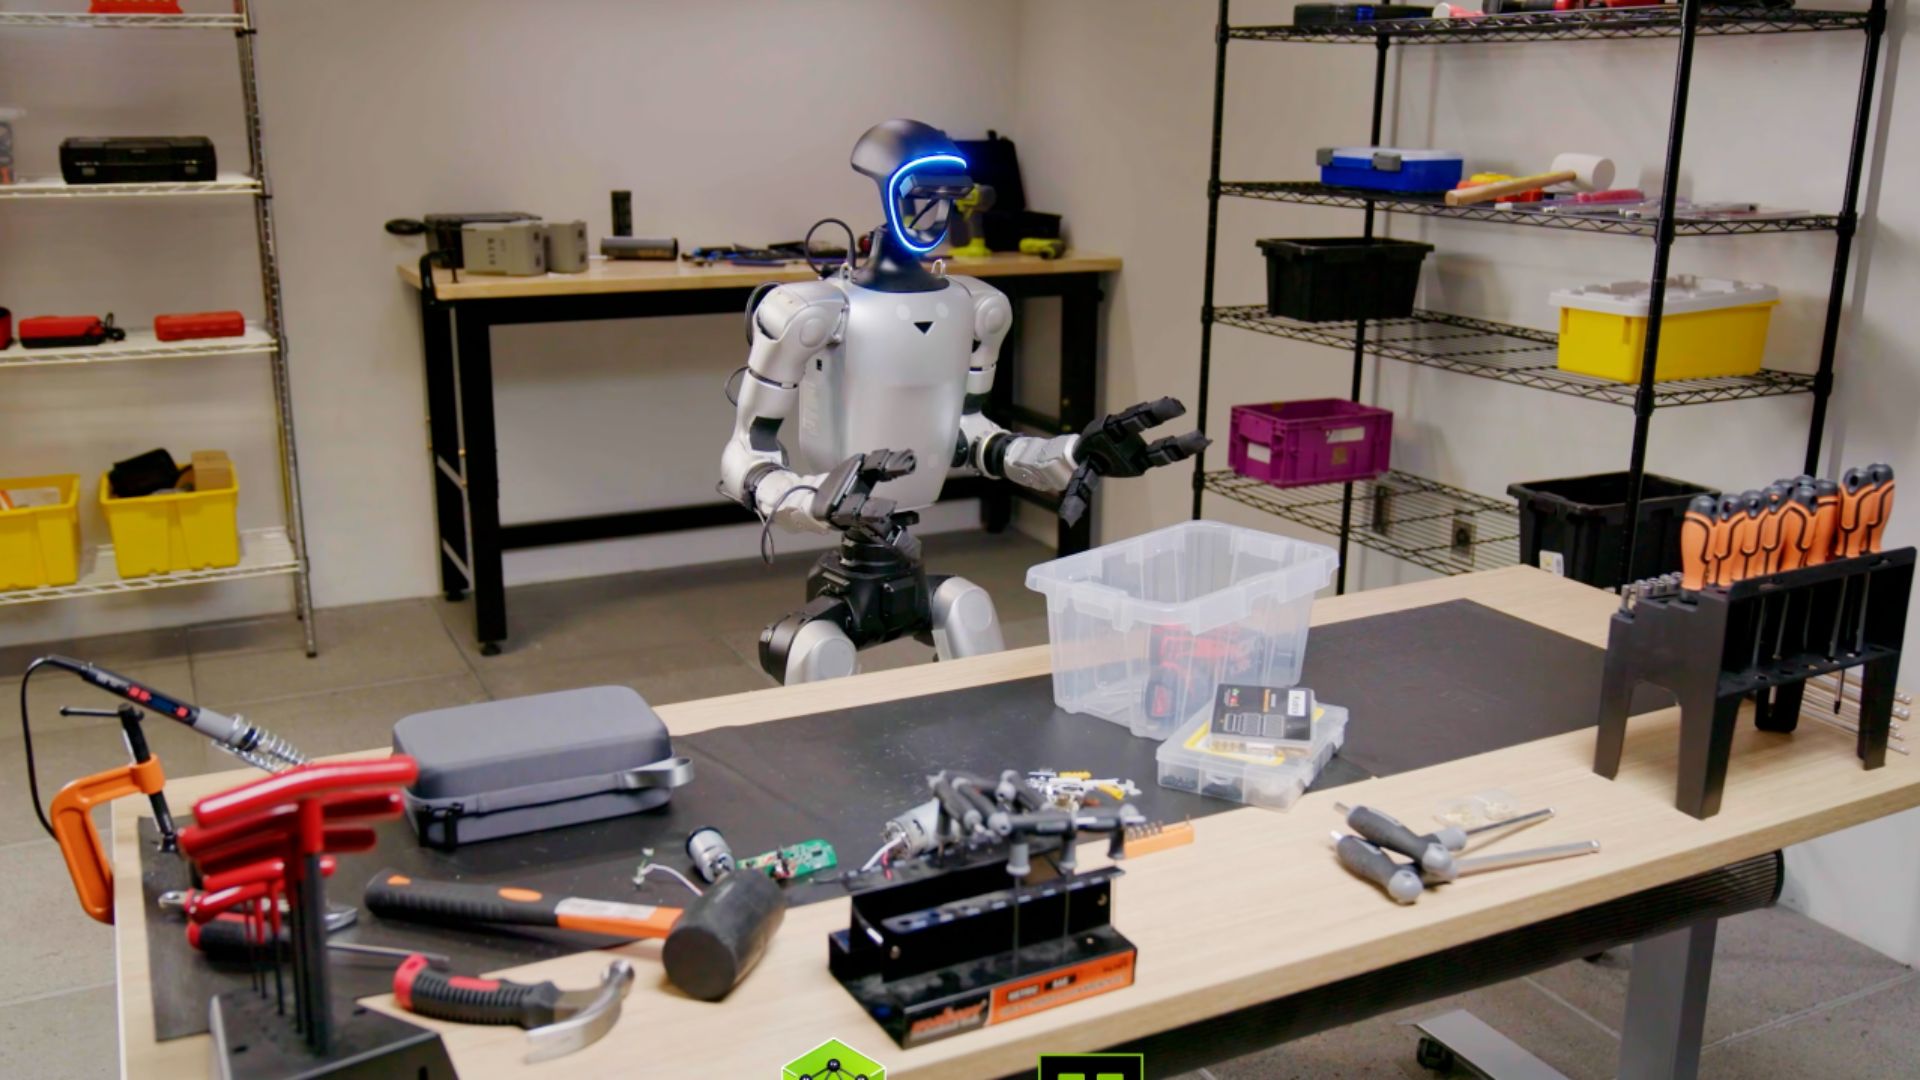
The world of robotics is witnessing a remarkable breakthrough with the introduction of SONIC, a groundbreaking humanoid robot system that revolutionizes the way machines move and interact. This innovative technology, developed by researchers at NVIDIA, enables robots to perform a wide range of natural movements, from running and jumping to grasping and dancing, all with the help of simple commands. What sets SONIC apart is its ability to seamlessly integrate various input methods, including teleoperation, video, text, and music, into a unified control framework.
One of the key strengths of SONIC lies in its scalable approach to humanoid control. Unlike traditional controllers designed for specific tasks, SONIC employs a single policy trained on an extensive dataset of over 100 million motion frames. This allows the robot to learn and reproduce diverse movements while demonstrating an impressive ability to generalize to new motions unseen during training. By treating motion tracking as a scalable learning problem, SONIC addresses a significant limitation in humanoid robotics, where existing control policies often require separate engineering and training for each new behavior.
The development of SONIC involved a meticulous scaling process across three dimensions: training data, model capacity, and computing power. The training dataset, derived from 700 hours of motion-capture data, contains over 100 million frames. The largest model, with 42 million parameters, was trained using an impressive 128 GPUs and approximately 21,000 GPU hours. As a result, the system's tracking and generalization capabilities improved significantly with each increase in these dimensions.
At the heart of SONIC's success is its universal token space, a clever mechanism that translates various motion inputs into a shared representation. Specialized encoders process robot motion, human motion, and hybrid commands, converting them into quantized tokens that feed into a common robot control decoder. This architecture enables the same control policy to handle motion tracking, VR teleoperation, video-based control, text commands, music-driven motion generation, and vision-language-action models, showcasing the system's versatility and adaptability.
SONIC's capabilities extend beyond its impressive motion tracking. It incorporates a real-time kinematic motion planner that generates short motion segments between keyframes, allowing for continuous adjustments in direction, speed, and movement style without the need for retraining. This feature enables interactive control, where the robot can adapt to changing commands in real-time, enhancing its responsiveness and versatility.
The researchers demonstrated SONIC's prowess by deploying it on a Unitree G1 humanoid robot, where it successfully tracked diverse motions in the real world. With a remarkable 99.2 percent success rate across 123 real-world motion sequences, SONIC exhibited a relatively small simulation-to-reality performance gap. Furthermore, when connected to a vision-language-action model, SONIC achieved an impressive average success rate of 75 percent in five whole-body tasks, showcasing its ability to handle complex interactions and tasks.
The potential implications of SONIC are far-reaching. By providing a shared action representation, it simplifies the control of the entire humanoid body, allowing higher-level AI systems to treat locomotion and manipulation as integrated problems. This development paves the way for more advanced general-purpose humanoid autonomy, where robots can seamlessly navigate and interact with their environment, opening up new possibilities for various industries and applications.
In conclusion, SONIC represents a significant leap forward in humanoid robotics, offering a scalable and versatile control framework that enables robots to perform a wide range of natural movements. Its ability to integrate diverse input methods and adapt to real-world scenarios makes it a powerful tool for advancing general-purpose humanoid autonomy. As researchers continue to refine and expand upon this technology, we can anticipate even more remarkable advancements in the field of robotics, shaping the future of human-machine interaction.